Description
Microduck MD-01: Open-Source Bipedal AI Robot for Learning Physical AI
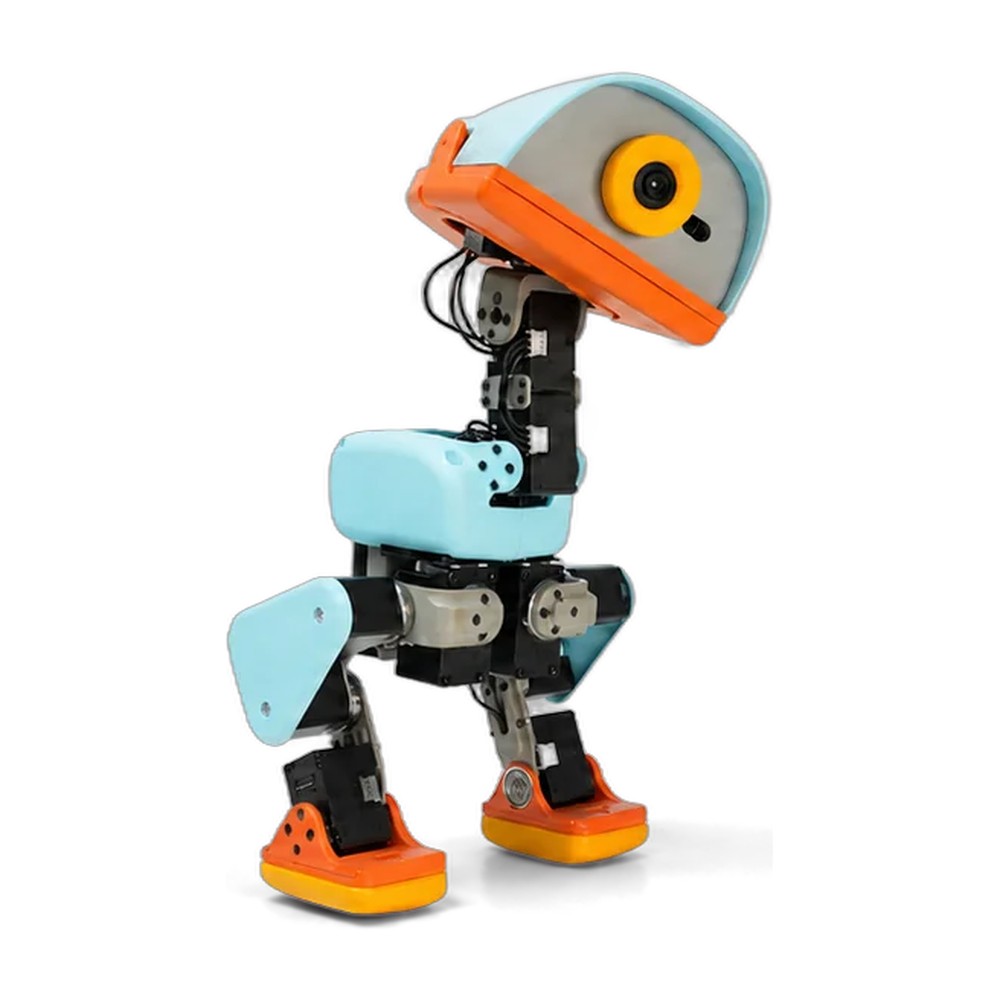
Microduck MD-01 is a new small bipedal robot from Pollen Robotics, part of Hugging Face, designed for learning robotics and physical AI. It is only 25 cm tall, weighs about 780 g and really walks, using 15 motors. You can start playing right away with the included gamepad, and when you are ready you can program it or train new behaviours yourself, because the software and simulation tools are fully open source. It suits schools and universities, research labs, AI developers and anyone who wants to get started with a walking robot on an accessible budget.
Microduck MD-01 Highlights
- Whole-body motion from 15 motors: it walks, crouches, picks things up with its moving beak and gets back up and keeps walking after a fall
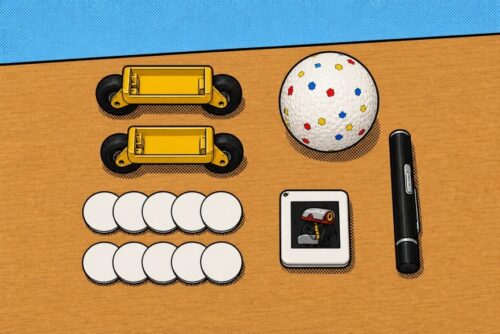
- Comes with 7 ready-made behaviours (policies) you can use right away, and can skate on optional rollers (included in the Accessory Pack)
- A full sensor set for AI work: a wide-angle front camera, an 8×8-zone ToF distance sensor, two IMUs, microphones and a speaker, plus NFC antennas in the head and beak
- On-board computing on a Rockchip RK3566 with an AI accelerator, running the control policy at 50 Hz
- Open-source software under the Apache-2.0 licence, with support for MuJoCo simulation, reinforcement-learning training and ONNX model export
- Removable NP-F550 battery, about 1 hour of use per battery
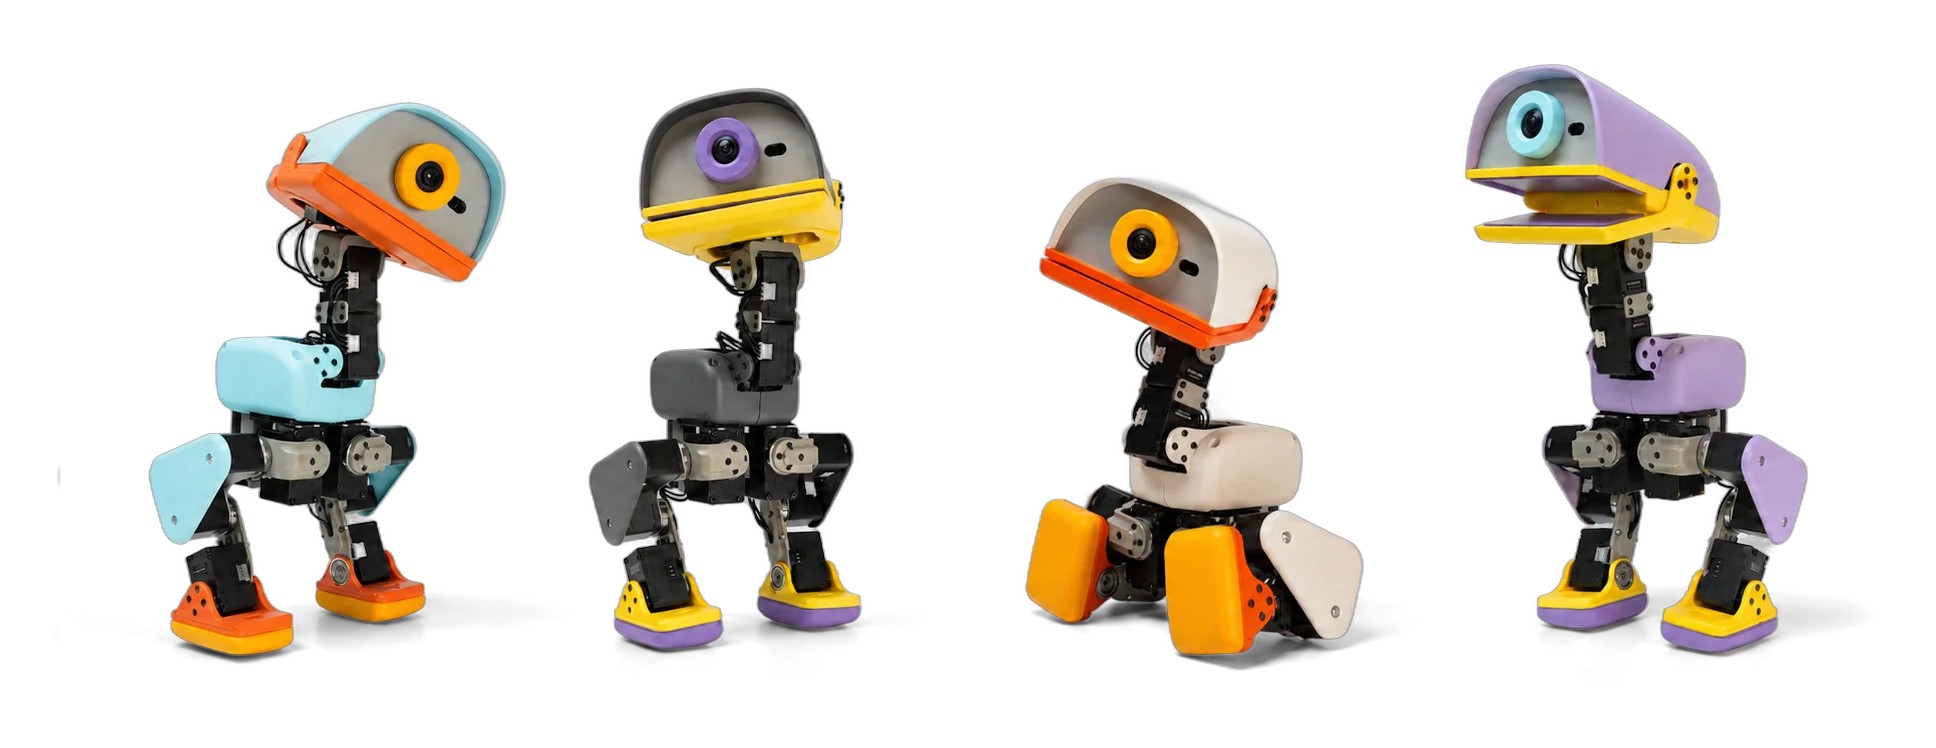
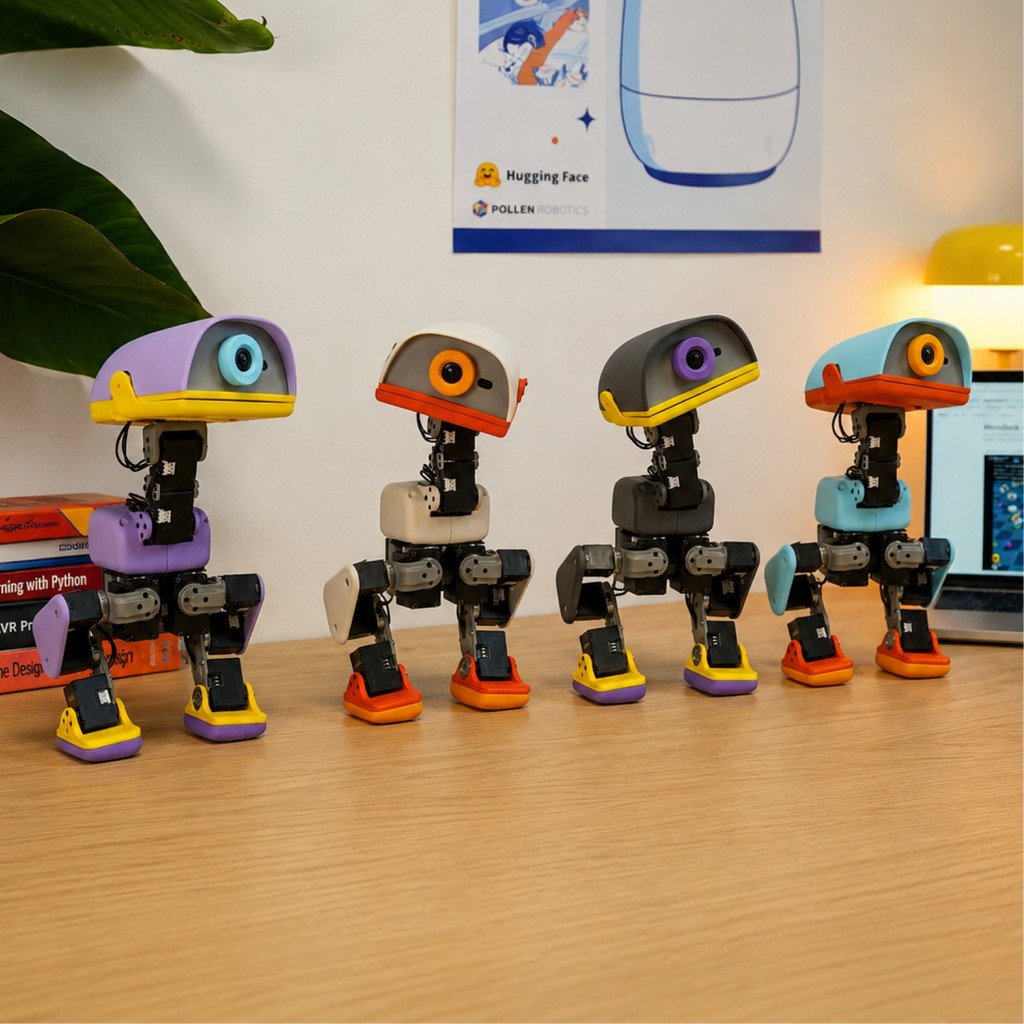
- Available in 4 colours: Cream, Graphite, Lavender and Sky
Train Your Own Walking Gait with NVIDIA Isaac Lab (Sim-to-Real)
NVIDIA, together with Pollen Robotics and Hugging Face, has published a workflow for teaching Microduck to walk with Isaac Lab, NVIDIA's framework for GPU-parallel robot training. It simulates physics with Newton and models the behaviour of the real servos, including gearbox play (backlash), so a gait trained on a computer transfers to the real robot (known as Sim-to-Real).
- Trains 4,096 environments in parallel at up to about 1.25 million steps per second, even with rough terrain and backlash modelling enabled
- Train on flat ground or on rough terrain with stairs and slopes, with randomised mass, friction, battery voltage, command latency and external pushes (domain randomization) so the robot walks reliably in the real world
- Export the model as an ONNX file, copy it to the robot over the network and load it with the robotctl command
- Test your model on the same challenges as other developers in Microduck Arena on Hugging Face Spaces
Key Specs
- Size: about 25 cm tall
- Weight: about 780 g
- Motors: 15
- Processor: Rockchip RK3566 with AI accelerator, 1 GB RAM, 32 GB storage
- Sensors: wide-angle front camera, 8×8 ToF LiDAR, 2 IMUs, microphones and speaker, 2 NFC antennas
- Connectivity: Wi-Fi and Bluetooth
- Battery: removable NP-F550, about 1 hour of use
- Software: open source (Apache-2.0), 50 Hz control policy, supports MuJoCo, NVIDIA Isaac Lab and ONNX
What's in the Box
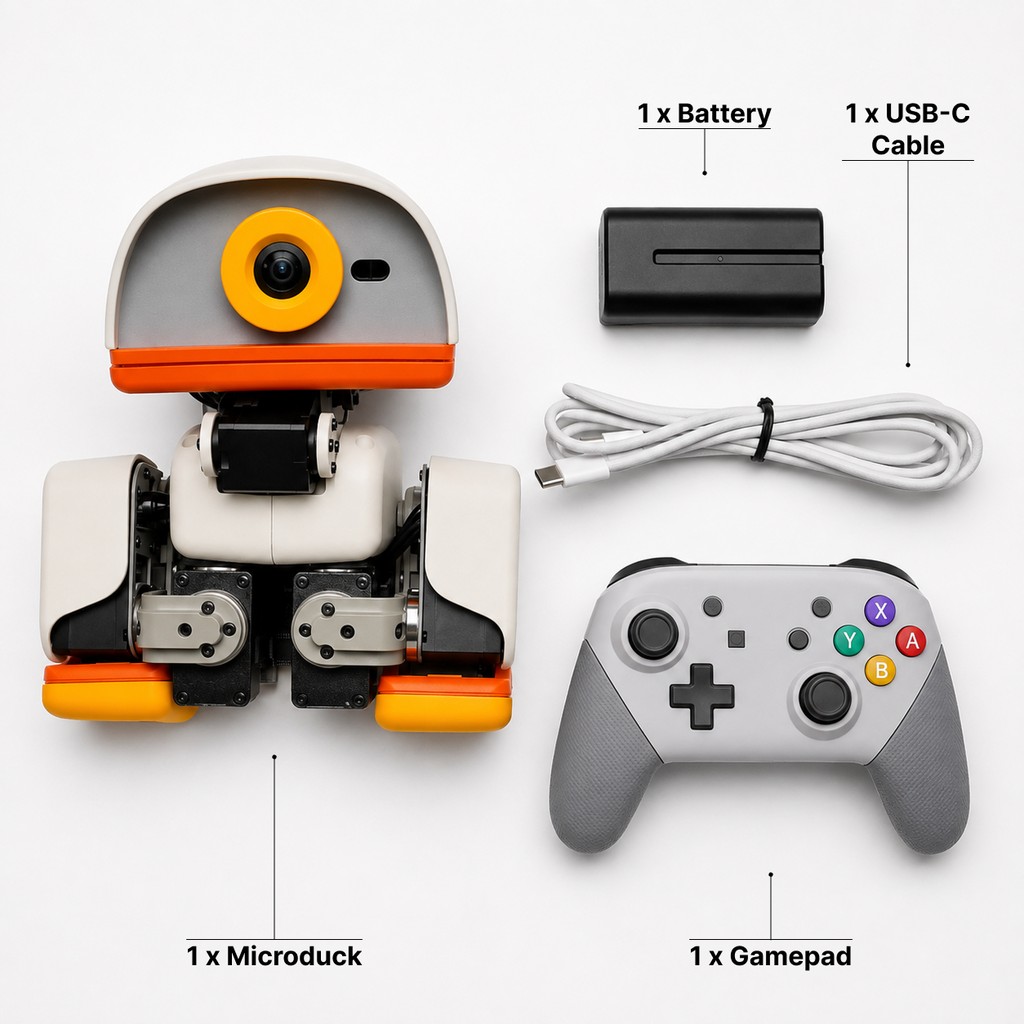
- 1 × Microduck MD-01 robot
- 1 × removable battery
- 1 × USB-C cable
- 1 × gamepad
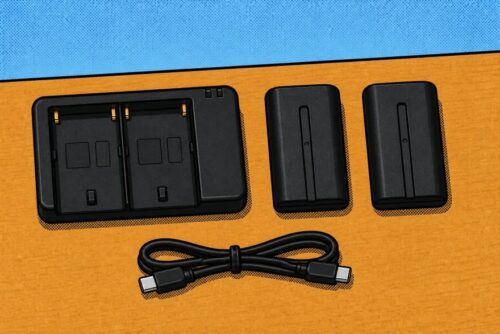
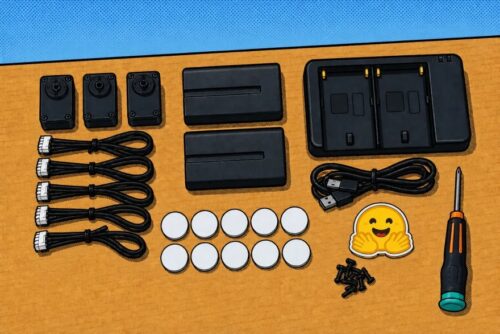
A USB-C power adapter and a development computer are not included. For extra equipment, choose from Microduck Charger Pack, Microduck Developer Pack and Microduck Accessory Pack
Microduck MD-01 is available for pre-order. The manufacturer aims to ship the first batch before Christmas 2026. For pricing and pre-orders, contact us on LINE ID: @metaxr

 Thai
 English
 Chinese
 Korean
 Japanese
Reviews
There are no reviews yet.